Continuous Let off Tension Control in Fine Gauge Tricot Fabrics
Continuous let-off tension control synchronizes beam spindle speed with needle consumption, preventing cyclic barré and mass variance in fine gauge tricot.
Beam
Fine gauge tricot production on 28E, 32E, and 40E warp knitting machines moves yarn from section beams into the needle zone at linear speeds exceeding 2,500 courses per minute. On a 32-gauge Karl Mayer or Liba machine running 22 dtex monofilament polyamide or 44 dtex/34 filament polyester, a single warp beam holds up to 134,000 metres of yarn wound across a 21-inch or 40-inch spool flange. As knitting proceeds, the external package diameter decreases from an initial 812 millimetres down to an empty spool core diameter of 152 millimetres.
This five-fold reduction in spool radius alters the mechanical leverage exerted by the yarn sheet upon the beam spindle. If beam rotational velocity remains constant, linear yarn speed collapses in direct proportion to the decreasing radius, which abruptly starves the knitting elements of yarn.
Mechanical let-off assemblies rely on friction bands, weighted dead-weight levers, or counter-rotating slip discs to control yarn release. Those mechanical arrangements respond to tension changes only after the yarn sheet exerts enough physical force to overcome static brake pad friction. In 15 dtex or 22 dtex ultra-fine yarn processing, the tensile load required to unseat a mechanical brake exceeds the elastic limit of the synthetic filaments.
The result is cyclic yarn necking, filament rupture, and erratic loop elongation across each knit cycle. Continuous let-off systems eliminate mechanical slip-stick resistance by decoupling warp delivery from yarn draw. A computer-controlled servo motor drives the warp beam spindle continuously, synchronizing delivery with the knitting machine main shaft via electronic gearing.
A tension spike of 0.8 centinewtons per end on 22 dtex polyamide shifts greige loop length by three percent before stitch knockover occurs.
Rotational inertia presents a severe mechanical disturbance during high-speed tricot formation. A fully wound 40-inch section beam loaded with continuous filament yarn possesses a mass exceeding 450 kilograms. When the knitting machine stops during an end break or yarn guide deflection, that rotating mass must decelerate from full operational velocity to a complete standstill within two machine revolutions.
Failure to arrest beam rotation instantly releases slack yarn into the guide bars. Slack yarn drops out of the sinker throats, snags on needle beards or compound needle sliders, and creates press-offs across thousands of ends. Conversely, when the machine accelerates to full running speed, the drive motor must inject instantaneous torque into the beam spindle to match the linear consumption of the knitting cycle.
Without active torque management, initial yarn pull creates acute tension spikes that permanently stretch fine synthetic filaments beyond their yield point.
Warp beams also present mechanical runout and eccentric circumference variations resulting from uneven flange alignment or winding compaction defects. A flange deflection of 0.5 millimetres creates an eccentric wobble that modulates yarn delivery tension once per beam revolution. At 800 millimetres spool diameter, that cyclic disturbance recurs every 2.5 metres of delivered yarn.
As the package depletes toward 160 millimetres diameter, the identical mechanical eccentricity creates a tension oscillation every 0.5 metres. Uncontrolled continuous delivery replicates these mechanical revolutions as visible periodic horizontal bands across the finished cloth. The supplier typically attributes these cyclic bands to yarn supplier package dye variation rather than beam arbor runout.
Feedback
Continuous electronic let-off mechanisms govern yarn delivery through either indirect calculation loops or direct force transducer loops. Indirect electronic let-off systems compute required beam rotational speed using main shaft angle sensors combined with non-contact laser or ultrasonic sensors that continuously read beam radius. As the package diameter shrinks, the digital controller calculates instantaneous surface speed, modulating servo motor output frequency to preserve a constant linear run-in rate.
This open-loop calculation method eliminates mechanical contact with delicate filaments, protecting low-twist microfibre yarns from mechanical abrasion along the yarn path.
Indirect radius calculation models fail to detect yarn compaction variations within the beam winding. If warping density shifts between the inner core and the outer circumference, the calculated radius diverges from the actual delivered yarn length per spool revolution. High-precision fine gauge tricot manufacturing therefore integrates closed-loop tension sensing along the yarn sheet.
Closed-loop systems route the warp sheet over a low-inertia, carbon-fibre sprung dancer bar or an array of load-cell guide rollers positioned between the beam stand and the guide bars. The sensor measures instantaneous yarn sheet deflection force, transmitting continuous analog voltage signals into the servo amplifier.
| Sensor Mechanism | Sampling Frequency | Tension Resolution | Permissible Yarn Deflection | Mechanical Inertia |
|---|---|---|---|---|
| Strain-Gauge Load Cell Roller | 2,000 Hertz | 0.05 centinewtons | 0.1 millimetres | 120 gram-centimetres squared |
| Carbon-Fibre Torsion Dancer Bar | 1,000 Hertz | 0.10 centinewtons | 4.5 millimetres | 45 gram-centimetres squared |
| Non-Contact Optical Triangulation | 250 Hertz | Calculated only | Zero contact | Zero added mass |
| Piezoelectric Quartz Transducer | 5,000 Hertz | 0.02 centinewtons | 0.05 millimetres | 180 gram-centimetres squared |
Warp tension oscillates within every knitting cycle. As the guide bars swing through the needles and the needle bar rises to accept the yarn overlap, tension rises to an operational peak. As needles descend through the cast-off position and the knockover sinkers advance, yarn demand drops, causing momentary slack.
Fine gauge tricot machines running at 2,800 courses per minute complete this cycle in approximately 21 milliseconds. Mechanical servo drives cannot accelerate and decelerate the heavy beam package within a 21-millisecond window. The continuous let-off drive maintains average linear velocity, while the lightweight sprung tension bar absorbs intra-cycle cyclic peaks.
- The guide bars swing across the needle gap, lifting yarn demand and deflecting the carbon-fibre dancer bar downward against calibrated leaf springs.
- The positional sensor on the dancer pivot detects angular displacement beyond the zero-point deadband, feeding an error voltage to the motion controller.
- The controller applies proportional-integral-derivative algorithms to calculate the necessary angular acceleration for the primary AC servomotor.
- The servomotor adjusts spindle RPM through an anti-backlash planetary reduction gearbox, restoring target dancer position within 120 milliseconds.
Dancer bar mass must remain negligible to prevent mechanical resonance at high speeds. If the natural frequency of the sprung sensing assembly matches the machine operating speed, harmonic oscillation destabilizes the servo control loop. When harmonic flutter occurs, the servo motor chases phantom tension peaks, injecting severe physical tension waves into the yarn sheet.
Dampening assemblies and low-mass carbon composite tubes prevent these mechanical resonance conditions during extended production runs.
A dancer bar assembly vibrating at machine harmonic frequency produces alternating tight and slack wales across entire production pieces.
The control algorithm must separate short-term stitch formation fluctuations from the long-term steady decrease in beam radius. Filtering circuits reject high-frequency signals generated by guide bar shogs while responding instantly to persistent base tension drift. Whether modern multi-axis servomotor firmware can completely decouple intra-stitch mechanical vibration from beam radius decay without sacrificing transient load response remains open to ongoing machine development.
Distortion
Tension variations during warp knitting generate severe structural defects in fine gauge tricot textiles. When yarn delivery tension fluctuates by as little as 0.2 centinewtons per end on a 32-gauge locknit or jersey construction, the loop geometry distorts instantly. Tricot relies on the mechanical balance between two or more guide bar yarn systems.
In a classic two-bar plain tricot (front bar knitting 1-0/1-2 and back bar knitting 2-3/1-0), the front bar yarn forms the face wales while the back bar yarn forms the structural underlaps. If front bar let-off tension rises while back bar tension remains static, the front bar pulls the underlaps tightly over the technical back, reducing fabric width and creating severe edge curl.
Uneven yarn consumption ratios between guide bars alter finished physical parameters. When back bar let-off delivers excess yarn, the extended underlaps sag across the needle space. These loose underlaps snag during subsequent wet processing stages, resulting in broken filaments and surface fuzzing.
If back bar let-off restricts delivery, the yarn robs thread from the front loops during stitch knockover, distorting the upright orientation of the wales. The resulting knitted cloth exhibits skewed loops, irregular light reflection, and persistent optical barré.
- Optical Barré Banding appears as transverse horizontal streaks across the knitted roll, caused by cyclical tension fluctuations altering loop shading under standard artificial illumination.
- Loop Robbing Distortion occurs when high back-bar tension pulls yarn directly out of adjacent front-bar loops at knockover, generating asymmetrical loop heads and erratic surface grain.
- Widthwise Greige Edge Curling develops when differential let-off tension skews yarn elastic recovery, causing the cloth selvedges to roll tightly inward during batching.
- Differential Dye Uptake Striations arise when excessive let-off tension strains synthetic filaments past their yield point, permanently altering crystalline orientation and dye site accessibility.
Filament elongation under variable let-off tension impacts wet processing performance. Polyamide 6 and polyamide 6,6 yarns drawn under high warp tension exhibit altered molecular orientation. Stretched molecular chains align more parallel to the filament axis, increasing crystallinity and reducing dye diffusion rates during subsequent aqueous coloration.
When tension drifts during beam depletion, the fabric knits with varying levels of latent mechanical strain.
During beam dyeing or jet dyeing in pressurized vessels, high-tension sections resist dye liquor penetration while adjacent low-tension sections absorb dye rapidly. The finished goods present shade variations that cannot be leveled by scouring or thermal finishing. When continuous tension control fails at the knitting machine, entire commercial dye lots fail visual tolerance standards under multi-illuminant light box inspection, forcing the direct rejection of finished rolls at the inspection frame.
Arithmetic
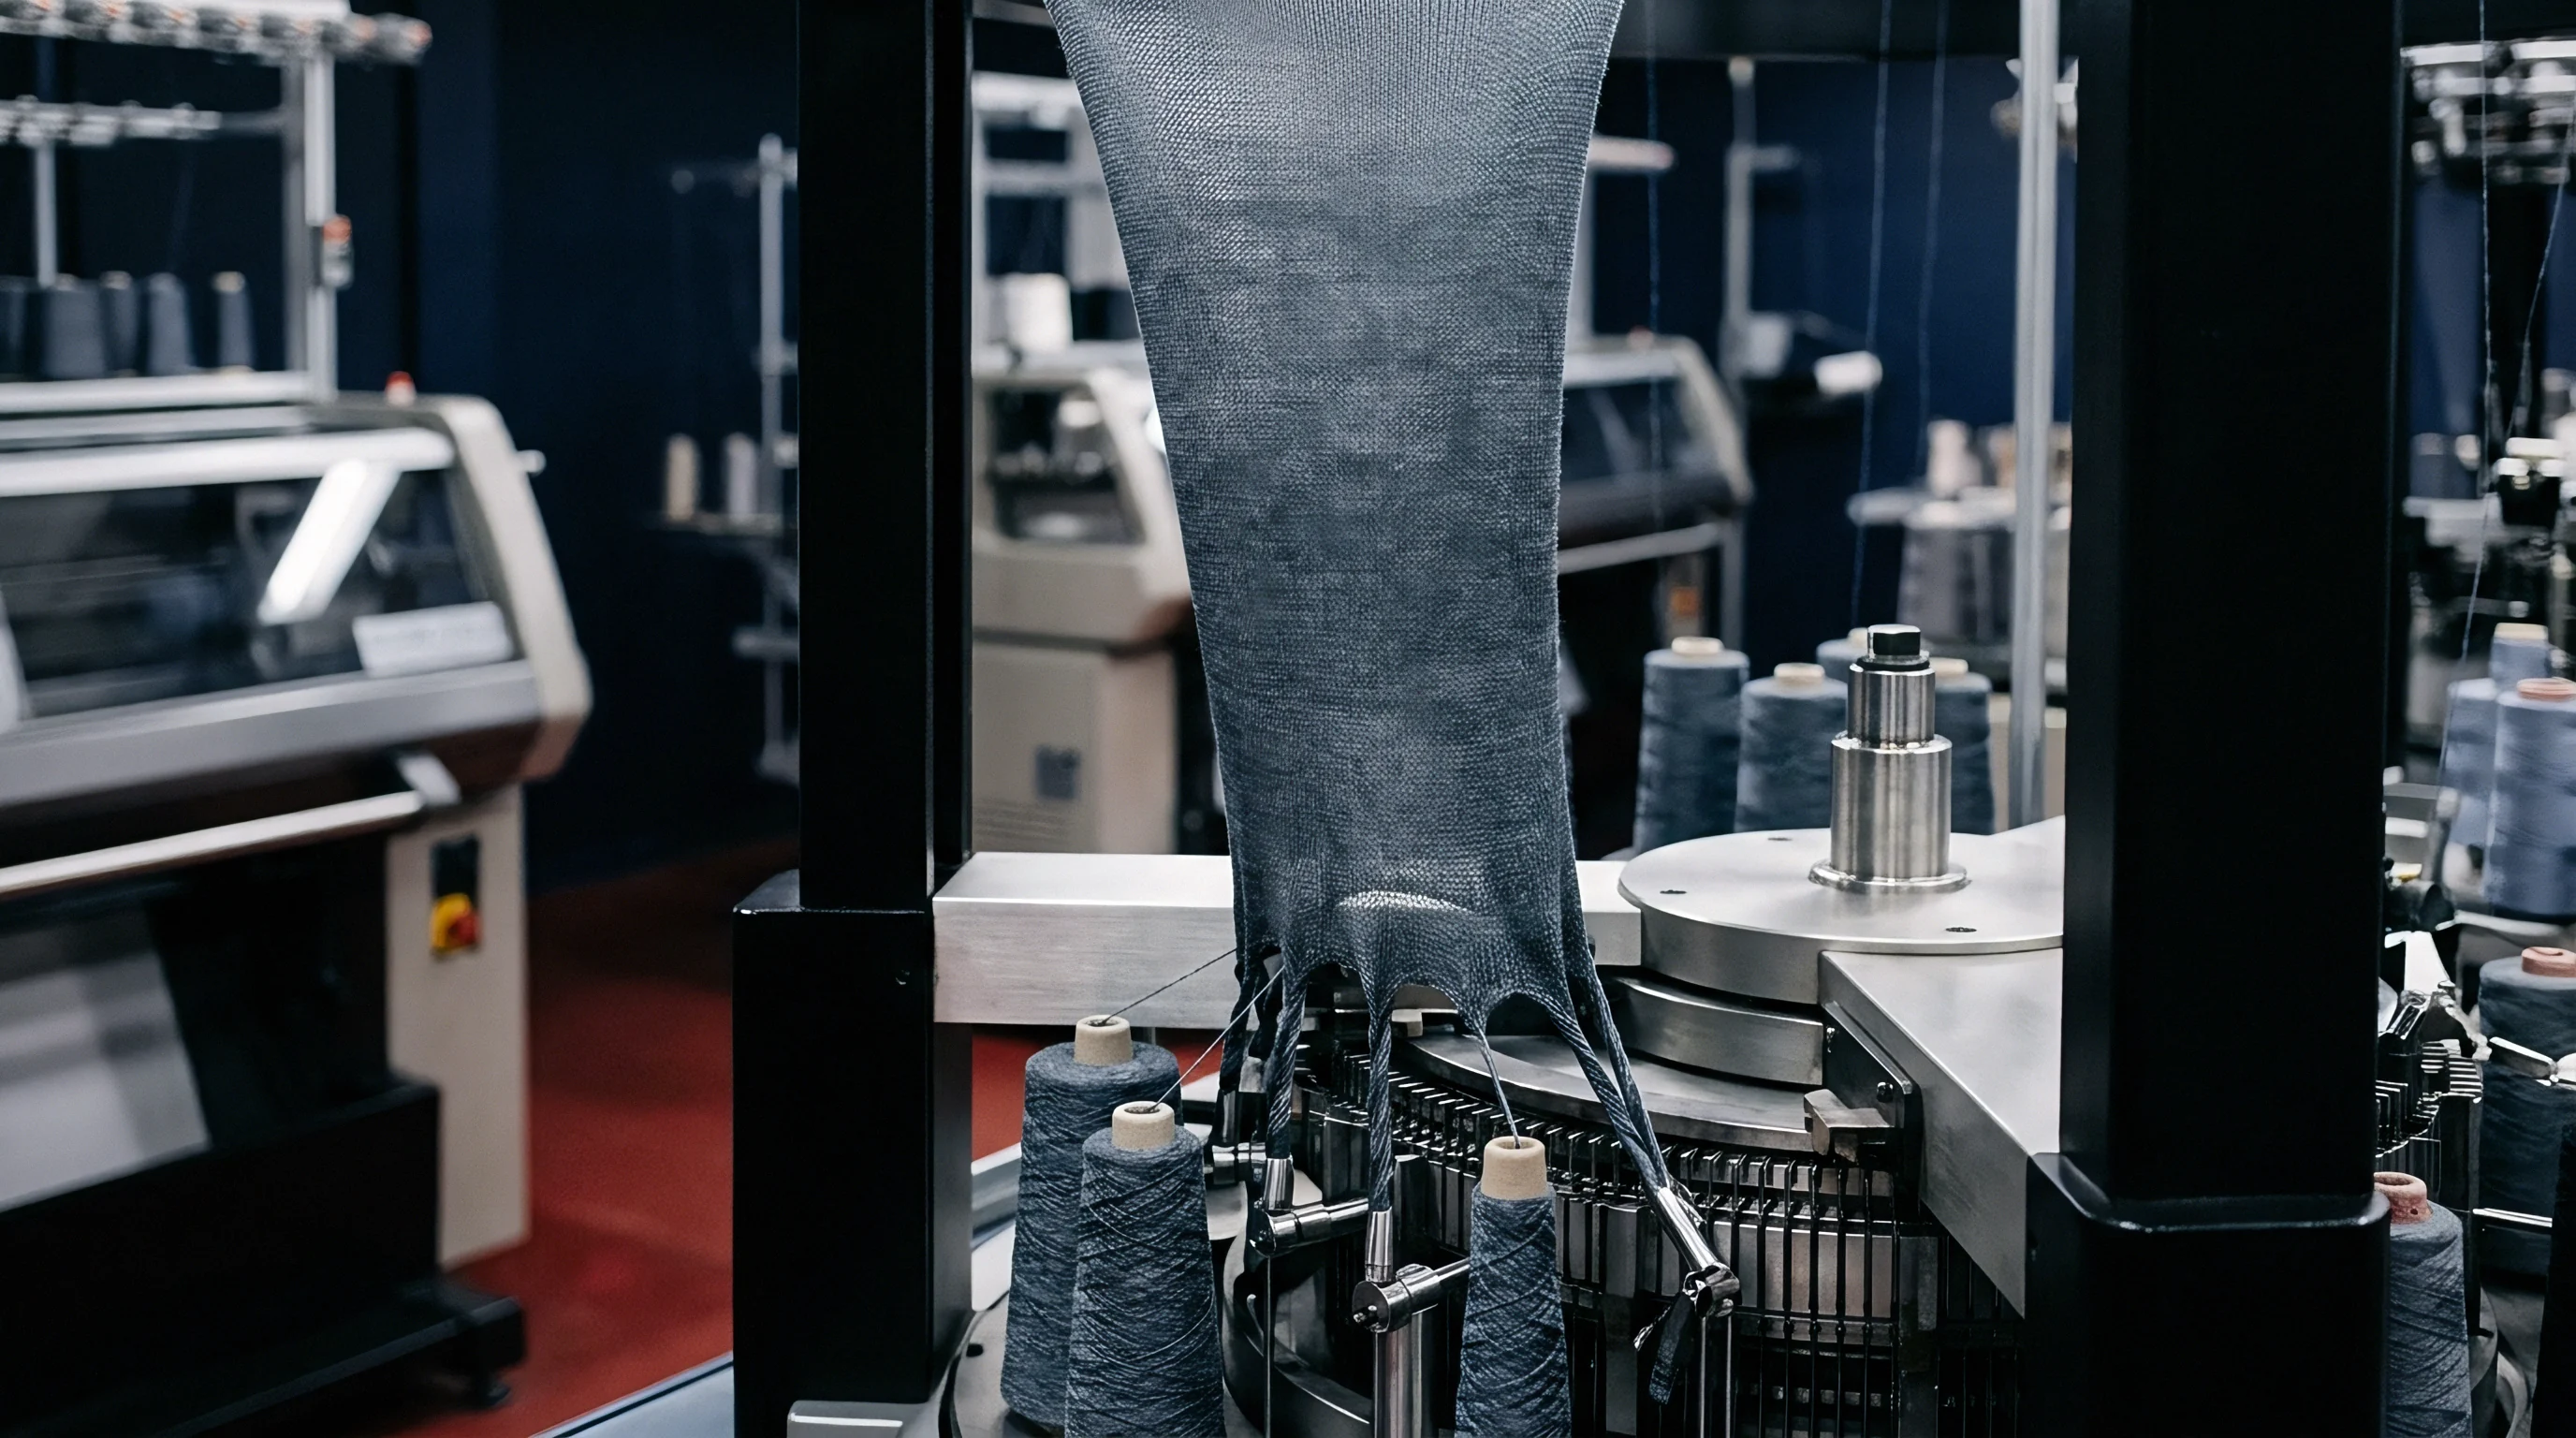
Warp run-in calculations govern quality verification in continuous tricot production. Run-in defines the linear length of yarn in millimetres consumed from a single warp beam to knit one complete rack of 480 courses. On multi-bar machines, each warp system operates with an independent, precisely specified run-in value.
If a technical data sheet specifies a front bar run-in of 1,520 millimetres per rack and a back bar run-in of 1,210 millimetres per rack, the resulting run-in ratio is 1.256 to 1. Maintaining this ratio across an entire 130,000-metre beam set guarantees uniform mass, recovery, and yield in finished cloth.
To evaluate let-off performance, examine a worked operational scenario. Assume a three-bar tricot machine running 32E gauge with 1,600 millimetres nominal working width, operating at 2,400 courses per minute on fine synthetic sportswear cloth. The machine consumes 5 racks per minute.
Table 2 details the target run-in values, permissible mechanical tolerances, and resulting yarn consumption parameters across three distinct guide bars.
| Guide Bar Position | Yarn Count | Target Run-In | Permissible Tolerance | Linear Delivery Speed | Tension Target |
|---|---|---|---|---|---|
| Front Bar (GB 1) | 22 dtex / 7f Polyamide 6 | 1,650 mm/rack | +/- 8 mm/rack | 8.25 m/min | 2.8 cN/end |
| Middle Bar (GB 2) | 44 dtex / 34f Polyester | 1,320 mm/rack | +/- 6 mm/rack | 6.60 m/min | 4.2 cN/end |
| Back Bar (GB 3) | 44 dtex Elastane | 620 mm/rack | +/- 4 mm/rack | 3.10 m/min | 7.5 cN/end |
Let us calculate the financial and physical impact when continuous let-off tension drifts on the front bar. Assume let-off motor feedback drift causes the front bar run-in to creep from 1,650 millimetres per rack upward to 1,695 millimetres per rack, an uncorrected error of 45 millimetres per rack (+2.7 percent drift). Over a standard 1,000-metre greige production roll containing 6,000 racks of cloth, this drift consumes 270,000 additional millimetres (270 metres) of yarn per warp end.
Across a 32-gauge needle bed spanning 1,600 millimetres, the machine knits with 2,016 warp ends per guide bar.
Total excess front yarn consumption equals 2,016 ends multiplied by 270 metres, yielding 544,320 metres of over-delivered 22 dtex yarn. With 22 dtex yarn weighing 2.2 grams per 1,000 metres, this let-off drift injects 1.197 kilograms of excess raw yarn mass into the roll. The greige fabric weight rises from an engineered target of 85.0 grams per square metre to 87.3 grams per square metre.
Over a typical 50,000-metre production contract, this unmonitored let-off error consumes 59.8 kilograms of unrecovered synthetic filament. More critically, the increased run-in elongates the technical face loops, decreasing bursting strength under ISO 13938-1 pneumatic diaphragm testing by 14 percent.
A run-in ratio error unchecked at the knitting frame expands across wet finishing into an irreversible fabric yield deficit.
Modern electronic beam control systems use high-resolution rotary optical encoders mounted directly to the warp beam spindle. An encoder providing 10,000 pulses per revolution allows the microprocessor to detect minute angular misalignments down to 0.036 degrees. The controller continuously samples pulse frequency against main shaft pulse generators.
When angular position drifts by more than two pulses from the calculated setpoint, the digital drive modulates voltage output to correct spindle position. Operators running fine gauge elastane warps inspect yarn balance markings manually every 500 racks to confirm that electronic encoder data matches physical beam consumption.
Stable loop formation relies on matching yarn feed exactly to needle consumption across the entire operational speed range.
Acceptance
Procuring fine gauge tricot textiles for technical apparel or automotive lining applications requires rigorous mill audits targeting warp preparation and knitting machine control architectures. Sourcing buyers frequently evaluate fabric samples based solely on weight and handfeel swatches, ignoring the machine generation running in the knitting shed. A mill running forty-year-old tricot frames equipped with mechanical band brakes cannot maintain the tension tolerances necessary for 20 dtex microdenier or elastane-plated constructions.
Technical audits must inspect the physical beam stands, verifying the presence of digital servo let-off drives, independent multi-axis control modules, and dynamic dancer or load-cell sensing assemblies.
Audit inspections must examine beam warping consistency in the warper room before evaluating knitting machines. Even the most responsive electronic let-off drive cannot compensate for section beams warped with uneven cross-flange yarn density. If the warping creel exerts variable tension across individual threadlines, the beam stores localized tight and slack bands across its width.
Continuous let-off rotates the beam as a rigid mechanical cylinder, releasing the identical linear circumference across all 2,000 ends. Threads wound under high tension remain tight, while threads wound under low tension sag into the guide bars. Technical qualification protocols mandate that warp beams display cross-beam density variations below 1.5 percent when checked with an electronic Shore durometer across eight equidistant points.
Contractual acceptance schedules that specify finished roll mass without binding greige run-in tolerances permit mills to mask yarn delivery drift through aggressive stenter overfeed.
Commercial sourcing contracts must define strict greige run-in tolerances alongside finished fabric parameters. Sourcing specifications should stipulate continuous run-in logging systems, requiring the mill to provide automated electronic let-off log files for every produced batch. These data logs track front-bar, middle-bar, and back-bar run-in values course-by-course across every roll.
Contractual clauses must establish that any roll exhibiting run-in fluctuations exceeding plus or minus 1.0 percent from technical specification sheet targets is subject to full commercial rejection prior to wet processing.
Buyers protect their supply chain by inserting a mandatory clause into master purchase agreements: The vendor warrants that all fine gauge tricot lots are produced on warp knitting frames equipped with closed-loop electronic continuous let-off drives, maintaining yarn delivery run-in within +/- 0.8 percent of approved counter-sample values, with full digital machine logs archived and accessible for eighteen months following batch release.